Physicl has raised $10 million in seed funding from Inovia Capital to help robot developers train physical AI systems using more realistic digital environments. The company was founded by Alex de Vigan, who is adapting 3D technology developed at his previous venture for robotics applications.
Training robots to handle objects in varied settings remains challenging. Video-based training can fall short, while collecting real-world data through remote operation can be costly. Physicl aims to address this gap with simulations designed to represent geometry, materials and physics more accurately.
Building targeted synthetic training data
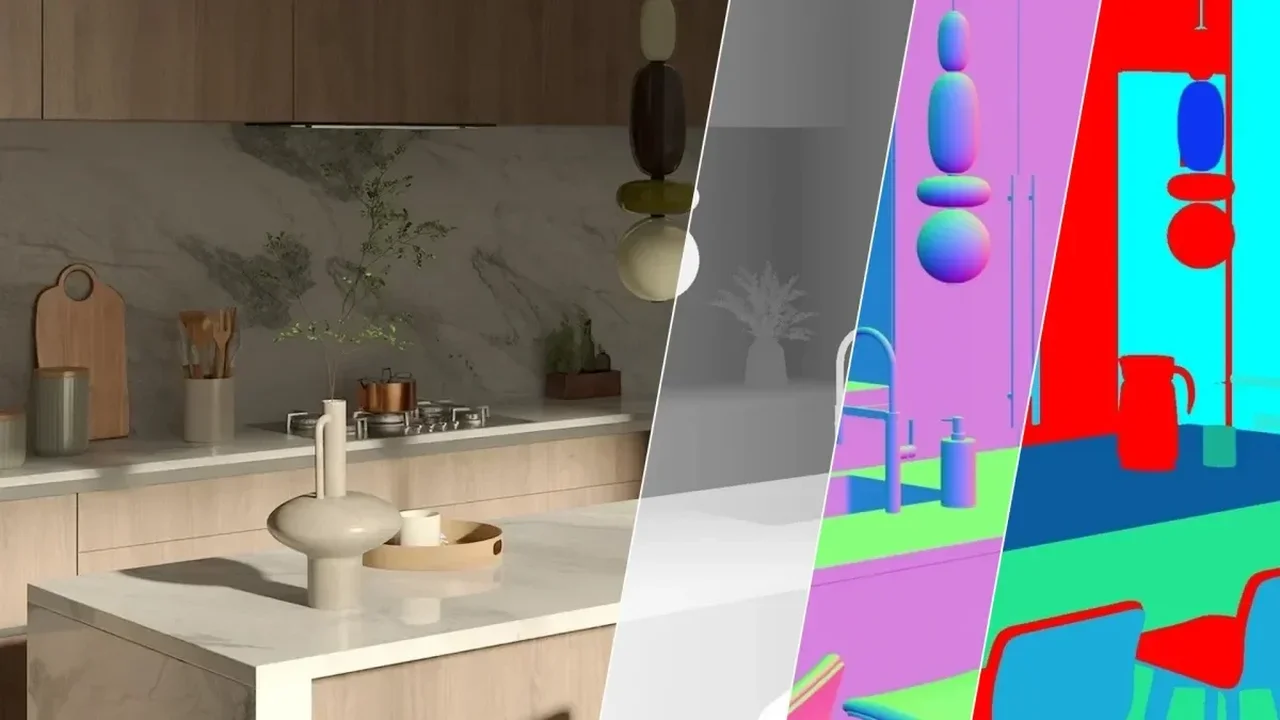
The startup's Studio product includes 10,000 3D environments and 100,000 digital assets. Users can assemble scenes and generate synthetic data for specific robot-training needs, such as identifying a cup on a cluttered surface or in a shadowed area.
World-model developer SpAItial has worked with Physicl as an early customer, using its synthetic data to improve the fidelity of 3D simulations generated from 2D imagery.
Physicl's broader goal is to help teams create training data on demand, adjusting simulations to address gaps that emerge as models are trained. If the approach scales, more lifelike digital environments could make robot development more adaptable and efficient.