As generative AI moves from screens into physical machines, robot developers are focusing on a defining question: how can autonomous systems work confidently around people in changing real-world environments?
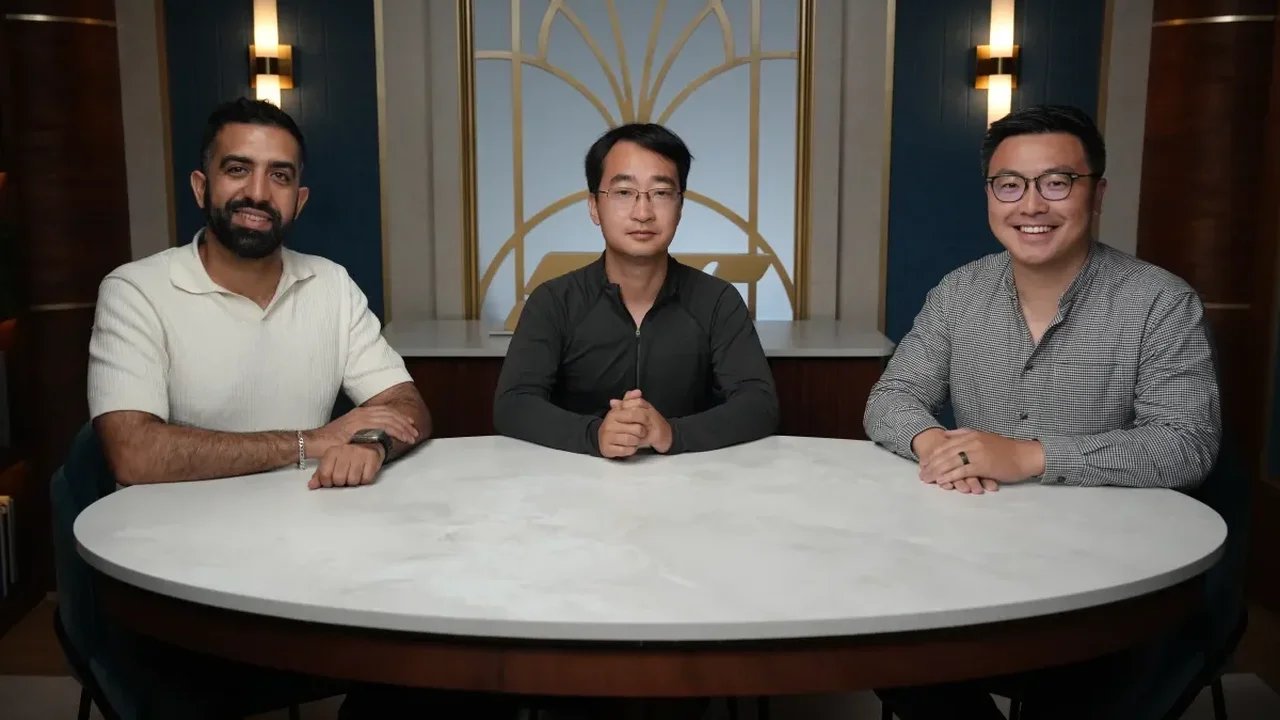
New robotics safety company Safeworld, founded by Carnegie Mellon University researcher Dr. Ding Zhao alongside Kyle Wong and Simo Rachidi, is developing simulation-based tools designed to evaluate how AI-powered robots respond to human activity before deployment.
Testing real-world complexity in virtual environments
Unlike traditional software, generative AI systems can produce different responses depending on context. Safeworld addresses this uncertainty by creating digital versions of workplaces and testing robotic control systems across thousands of possible scenarios.
Its platform can model settings such as factory walkways, blind corners and active industrial sites. Virtual human models may walk, carry equipment, crouch, run or move unpredictably, allowing developers to assess a robot's awareness, speed and stopping behavior under varied conditions.
The company uses simulations powered by the robot's own software, rather than relying only on controlled demonstrations. This approach aims to give manufacturers a more practical understanding of how robotic systems may perform in dynamic settings shared with workers.
A shared standard for human-robot collaboration
Safeworld has secured more than $12 million in seed funding and is working with robotics companies including Gritt Robotics, which develops systems for large-scale solar installation projects. The collaboration focuses on evaluating robotic arms and other equipment designed to operate alongside human teams.
The founders also see an opportunity for independent validation across the sector. As robots enter more workplaces, a third-party safety assessment process could help organizations compare testing methods and build common expectations around responsible deployment.
With physical AI advancing rapidly, simulation-led safety evaluation could become a core foundation for more reliable, adaptable and human-centered robotics in the future.